


Core Research Institute of Intelligent Robots JBNU, South Korea |

Jeonbuk National University South Korea |

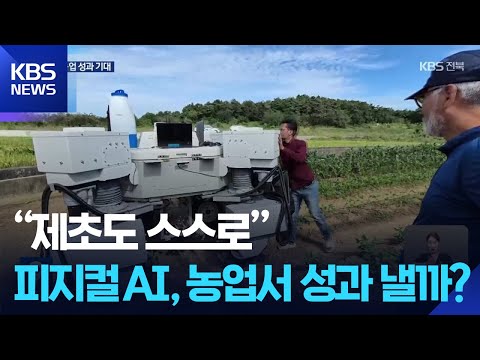
Field Weeding Robot Featured on KBS News |

Quaid-i-Azam University Islamabad, Pakistan · B.S. |



-
| Computer Vision | Robotics & Systems |
|---|---|
| 🔍 Semantic Segmentation | 🤖 Agricultural Robotics |
| 🌱 Precision Agriculture | ⚙️ ROS / Edge Deployment |
| 📏 Depth & RGB Perception | 🎯 Pin-Precision Actuation |
| 🔄 Domain Adaptation | 📡 Real-time Inference |
| 🧪 Knowledge Distillation | 🚜 Field Robot Systems |
| Project | Role | Coverage | Paper |
|---|---|---|---|
| Autonomous Crop-Management / Weeding Robot | Perception & deep-learning stack (co-author) | 📺 KBS News · |
📄 CEA 2025 |
Camera → crop/weed perception → pin-precision nozzles → field robot.
Covered by KBS (Sep 2025): “제초도 스스로”… 피지컬 AI, 농업에서 성과 낼까?
| Repository | Description | Year | Status |
|---|---|---|---|
| pidnet-cropweed | Real-time PIDNet-S crop–weed–soil segmentation · 0.887 mIoU · ~91 FPS | 2025 | ✅ Released |
| cropweed-kd | Knowledge distillation · DeepLabV3+ teacher → ResNet18 / MobileNet student | 2025 | ✅ Released |
| advent-cropweed | ADVENT unsupervised domain adaptation for crop–weed–soil | 2025 | ✅ Released |
| road-lane-detection | Ego-camera road lane segmentation · DeepLabV3 / U-Net++ | 2024 | ✅ Released |
| crop-weed-segmentation | UAV Bonn crop vs weed U-Net · Grad-CAM | 2023 | ✅ Released |
| face-mask-detection | Face mask detection · OpenCV SSD + MobileNetV2 | 2020 | ✅ Released |
| Project | Technology | Demo / Links | Status |
|---|---|---|---|
| Pin-Precision Weeding Robot | PyTorch OpenCV ROS Edge AI |
✅ Deployed / Featured | |
| Real-time Crop–Weed Perception | PIDNet DeepLab KD |
pidnet-cropweed | ✅ Released |
| Project | Stack | Focus | Status |
|---|---|---|---|
| Domain-Adaptive Segmentation | ADVENT PyTorch |
Cross-field / weather shift | ✅ Released |
| Lane Perception | DeepLabV3 PyTorch |
Ego-camera driving scenes | ✅ Released |




💡 Open to collaboration on Computer Vision, Precision Agriculture, and Field Robotics
"Building perception systems that leave the lab and work on real machines outdoors"